The scenario_t structure and associated subroutines. More...
Data Types | |
| type | drydep_params_t |
| Parameters for simulating dry deposition. More... | |
| type | scenario_t |
| Scenario data. More... | |
Functions/Subroutines | |
| subroutine | scenario_init_env_state (scenario, env_state, time) |
| Initialize the time-dependent contents of the environment. Thereafter scenario_update_env_state() should be used. More... | |
| subroutine | scenario_update_env_state (scenario, env_state, time) |
| Update time-dependent contents of the environment. scenario_init_env_state() should have been called at the start. More... | |
| subroutine | scenario_update_gas_state (scenario, delta_t, env_state, old_env_state, gas_data, gas_state) |
| Do gas emissions and background dilution. More... | |
| subroutine | scenario_update_aero_state (scenario, delta_t, env_state, old_env_state, aero_data, aero_state, n_emit, n_dil_in, n_dil_out, allow_doubling, allow_halving) |
| Do emissions and background dilution for a particle aerosol distribution. More... | |
| subroutine | scenario_update_aero_binned (scenario, delta_t, env_state, old_env_state, bin_grid, aero_data, do_aero_dilution, aero_binned) |
| Do emissions and background dilution from the environment for a binned aerosol distribution. More... | |
| subroutine | scenario_update_aero_modes (aero_dist, del_t, env_state, density, scenario) |
| Update the modal aerosol distribution to account for particle loss. More... | |
| real(kind=dp) function | scenario_loss_rate (scenario, vol, density, aero_data, env_state) |
| Evaluate a loss rate function. More... | |
| real(kind=dp) function | scenario_loss_rate_drydep (vol, density, aero_data, env_state, scenario) |
Compute and return the dry deposition rate for a given particle. All equations used here are written in detail in the file doc/deposition/deposition.tex. More... | |
| real(kind=dp) function | scenario_integrated_loss_rate_drydep (scenario, aero_mode, moment, density, env_state) |
| Compute and return the integrated dry deposition rate for a given lognormal aerosol mode (modal approximation). More... | |
| subroutine | scenario_modal_drydep_velocities (scenario, aero_dist, moment, density, env_state, velocities) |
| Updates an array to contain the integrated deposition velocities for the given moment of each aerosol mode in the distribution. More... | |
| real(kind=dp) function | scenario_loss_rate_max (scenario, vol, aero_data, env_state) |
| Compute and return the max loss rate function for a given volume. More... | |
| subroutine | scenario_loss_rate_bin_max (scenario, bin_grid, aero_data, env_state, loss_max) |
| Compute an upper bound on the maximum kernel value for each bin. Value over_scale is multiplied to the maximum sampled value to get the upper bound. A tighter bound may be reached if over_scale is smaller, but that also risks falling below a kernel value. More... | |
| subroutine | scenario_particle_loss (scenario, delta_t, aero_data, aero_state, env_state) |
Performs stochastic particle loss for one time-step. If a particle i_part has a scenario_loss_rate() value of rate, then the probability p will be removed by this function is 1 - exp(-delta_t*rate). Uses an accept-reject algorithm for efficiency, in which a particle is first sampled with rate 1 - exp(-delta_t*over_rate) and then accepted with rate (1 - exp(-delta_t*rate))/(1 - exp(-delta_t*over_rate)). More... | |
| subroutine | scenario_try_single_particle_loss (scenario, delta_t, aero_data, aero_state, env_state, i_part, over_prob) |
| Test a candidate particle to see if it should be removed, and remove if necessary. Particle is removed with probability (1d0 - exp(-delta_t*rate))/over_prob, where rate is the loss function evaluated for the given particle. More... | |
| subroutine | scenario_binned_loss (scenario, bin_grid, delta_t, aero_data, env_state, aero_binned) |
| Performs loss for a binned aerosol distribution for one time step. More... | |
| elemental logical function | scenario_contains_aero_mode_type (scenario, aero_mode_type) |
| Whether any of the contained aerosol modes are of the given type. More... | |
| subroutine | drydep_params_output_netcdf (drydep_params, ncid) |
| Write dry deposition parameters to a NetCDF file. More... | |
| subroutine | drydep_params_input_netcdf (drydep_params, ncid, must_be_present) |
| Read dry deposition parameters from a NetCDF file. More... | |
| integer function | pmc_mpi_pack_size_scenario (val) |
| Determines the number of bytes required to pack the given value. More... | |
| subroutine | pmc_mpi_pack_scenario (buffer, position, val) |
| Packs the given value into the buffer, advancing position. More... | |
| subroutine | pmc_mpi_unpack_scenario (buffer, position, val) |
| Unpacks the given value from the buffer, advancing position. More... | |
| integer function | pmc_mpi_pack_size_drydep (val) |
| Determines the number of bytes required to pack the given value. More... | |
| subroutine | pmc_mpi_pack_drydep (buffer, position, val) |
| Packs the given value into the buffer, advancing position. More... | |
| subroutine | pmc_mpi_unpack_drydep (buffer, position, val) |
| Unpacks the given value from the buffer, advancing position. More... | |
Variables | |
| integer, parameter | scenario_loss_function_invalid = 0 |
| Type code for an undefined or invalid loss function. More... | |
| integer, parameter | scenario_loss_function_none = 1 |
| Type code for a zero loss function. More... | |
| integer, parameter | scenario_loss_function_constant = 2 |
| Type code for a constant loss function. More... | |
| integer, parameter | scenario_loss_function_volume = 3 |
| Type code for a loss rate function proportional to particle volume. More... | |
| integer, parameter | scenario_loss_function_drydep = 4 |
| Type code for a loss rate function based on dry deposition. More... | |
| integer, parameter | scenario_loss_function_chamber = 5 |
| Type code for a loss rate function for chamber experiments. More... | |
| real(kind=dp), parameter | scenario_loss_alg_threshold = 1.0d0 |
| Parameter to switch between algorithms for particle loss. A value of 0 will always use the naive algorithm, and a value of 1 will always use the accept-reject algorithm. More... | |
Detailed Description
The scenario_t structure and associated subroutines.
Function/Subroutine Documentation
◆ drydep_params_input_netcdf()
| subroutine pmc_scenario::drydep_params_input_netcdf | ( | type(drydep_params_t), intent(inout) | drydep_params, |
| integer, intent(in) | ncid, | ||
| logical, intent(in), optional | must_be_present | ||
| ) |
Read dry deposition parameters from a NetCDF file.
- Parameters
-
[in,out] drydep_params Dry deposition parameters. [in] ncid NetCDF file ID, in data mode. [in] must_be_present Whether the parameters must be present in the file (default .true.). They are only written when the loss function is dry deposition, so readers that may be given either kind of file should pass.false., which leavesdrydep_paramsunchanged.
Definition at line 1549 of file scenario.F90.
◆ drydep_params_output_netcdf()
| subroutine pmc_scenario::drydep_params_output_netcdf | ( | type(drydep_params_t), intent(in) | drydep_params, |
| integer, intent(in) | ncid | ||
| ) |
Write dry deposition parameters to a NetCDF file.
- Parameters
-
[in] drydep_params Dry deposition parameters. [in] ncid NetCDF file ID, in data mode.
Definition at line 1521 of file scenario.F90.
◆ pmc_mpi_pack_drydep()
| subroutine pmc_scenario::pmc_mpi_pack_drydep | ( | character, dimension(:), intent(inout) | buffer, |
| integer, intent(inout) | position, | ||
| type(drydep_params_t), intent(in) | val | ||
| ) |
Packs the given value into the buffer, advancing position.
- Parameters
-
[in,out] buffer Memory buffer. [in,out] position Current buffer position. [in] val Value to pack.
Definition at line 1804 of file scenario.F90.
◆ pmc_mpi_pack_scenario()
| subroutine pmc_scenario::pmc_mpi_pack_scenario | ( | character, dimension(:), intent(inout) | buffer, |
| integer, intent(inout) | position, | ||
| type(scenario_t), intent(in) | val | ||
| ) |
Packs the given value into the buffer, advancing position.
- Parameters
-
[in,out] buffer Memory buffer. [in,out] position Current buffer position. [in] val Value to pack.
Definition at line 1649 of file scenario.F90.
◆ pmc_mpi_pack_size_drydep()
| integer function pmc_scenario::pmc_mpi_pack_size_drydep | ( | type(drydep_params_t), intent(in) | val | ) |
Determines the number of bytes required to pack the given value.
- Parameters
-
[in] val Value to pack.
Definition at line 1780 of file scenario.F90.
◆ pmc_mpi_pack_size_scenario()
| integer function pmc_scenario::pmc_mpi_pack_size_scenario | ( | type(scenario_t), intent(in) | val | ) |
Determines the number of bytes required to pack the given value.
- Parameters
-
[in] val Value to pack.
Definition at line 1592 of file scenario.F90.
◆ pmc_mpi_unpack_drydep()
| subroutine pmc_scenario::pmc_mpi_unpack_drydep | ( | character, dimension(:), intent(inout) | buffer, |
| integer, intent(inout) | position, | ||
| type(drydep_params_t), intent(inout) | val | ||
| ) |
Unpacks the given value from the buffer, advancing position.
- Parameters
-
[in,out] buffer Memory buffer. [in,out] position Current buffer position. [in,out] val Value to pack.
Definition at line 1838 of file scenario.F90.
◆ pmc_mpi_unpack_scenario()
| subroutine pmc_scenario::pmc_mpi_unpack_scenario | ( | character, dimension(:), intent(inout) | buffer, |
| integer, intent(inout) | position, | ||
| type(scenario_t), intent(inout) | val | ||
| ) |
Unpacks the given value from the buffer, advancing position.
- Parameters
-
[in,out] buffer Memory buffer. [in,out] position Current buffer position. [in,out] val Value to pack.
Definition at line 1709 of file scenario.F90.
◆ scenario_binned_loss()
| subroutine pmc_scenario::scenario_binned_loss | ( | type(scenario_t), intent(in) | scenario, |
| type(bin_grid_t), intent(in) | bin_grid, | ||
| real(kind=dp), intent(in) | delta_t, | ||
| type(aero_data_t), intent(in) | aero_data, | ||
| type(env_state_t), intent(in) | env_state, | ||
| type(aero_binned_t), intent(inout) | aero_binned | ||
| ) |
Performs loss for a binned aerosol distribution for one time step.
- Parameters
-
[in] scenario Scenario data. [in] bin_grid Bin grid. [in] delta_t Time increment to update over. [in] aero_data Aerosol data. [in] env_state Environmental state. [in,out] aero_binned Binned aerosol data.
Definition at line 1136 of file scenario.F90.
◆ scenario_contains_aero_mode_type()
| elemental logical function pmc_scenario::scenario_contains_aero_mode_type | ( | type(scenario_t), intent(in) | scenario, |
| integer, intent(in) | aero_mode_type | ||
| ) |
Whether any of the contained aerosol modes are of the given type.
- Parameters
-
[in] scenario Scenario data. [in] aero_mode_type Aerosol mode type to test for.
Definition at line 1190 of file scenario.F90.
◆ scenario_init_env_state()
| subroutine pmc_scenario::scenario_init_env_state | ( | type(scenario_t), intent(in) | scenario, |
| type(env_state_t), intent(inout) | env_state, | ||
| real(kind=dp), intent(in) | time | ||
| ) |
Initialize the time-dependent contents of the environment. Thereafter scenario_update_env_state() should be used.
- Parameters
-
[in] scenario Scenario data. [in,out] env_state Environment state to update. [in] time Current time (s).
Definition at line 145 of file scenario.F90.
◆ scenario_integrated_loss_rate_drydep()
| real(kind=dp) function pmc_scenario::scenario_integrated_loss_rate_drydep | ( | type(scenario_t), intent(in) | scenario, |
| type(aero_mode_t), intent(in) | aero_mode, | ||
| real(kind=dp), intent(in) | moment, | ||
| real(kind=dp), intent(in) | density, | ||
| type(env_state_t), intent(in) | env_state | ||
| ) |
Compute and return the integrated dry deposition rate for a given lognormal aerosol mode (modal approximation).
- Parameters
-
[in] scenario Scenario data. [in] aero_mode Aerosol mode. [in] moment Moment to calculate loss rate for. [in] density Particle density assumed for entire mode (kg m^-3). [in] env_state Environment state.
Definition at line 646 of file scenario.F90.
◆ scenario_loss_rate()
| real(kind=dp) function pmc_scenario::scenario_loss_rate | ( | type(scenario_t), intent(in) | scenario, |
| real(kind=dp), intent(in) | vol, | ||
| real(kind=dp), intent(in) | density, | ||
| type(aero_data_t), intent(in) | aero_data, | ||
| type(env_state_t), intent(in) | env_state | ||
| ) |
Evaluate a loss rate function.
- Parameters
-
[in] scenario Scenario data. [in] vol Volume of particle (m^3). [in] density Density of particle (kg/m^3). [in] aero_data Aerosol data. [in] env_state Environment state.
Definition at line 506 of file scenario.F90.
◆ scenario_loss_rate_bin_max()
| subroutine pmc_scenario::scenario_loss_rate_bin_max | ( | type(scenario_t), intent(in) | scenario, |
| type(bin_grid_t), intent(in) | bin_grid, | ||
| type(aero_data_t), intent(in) | aero_data, | ||
| type(env_state_t), intent(in) | env_state, | ||
| real(kind=dp), dimension(bin_grid_size(bin_grid)), intent(out) | loss_max | ||
| ) |
Compute an upper bound on the maximum kernel value for each bin. Value over_scale is multiplied to the maximum sampled value to get the upper bound. A tighter bound may be reached if over_scale is smaller, but that also risks falling below a kernel value.
- Parameters
-
[in] scenario Scenario data. [in] bin_grid Bin_grid. [in] aero_data Aerosol data. [in] env_state Environment state. [out] loss_max Maximum loss vals.
Number of sample points per bin.
Over-estimation scale factor parameter.
Definition at line 965 of file scenario.F90.
◆ scenario_loss_rate_drydep()
| real(kind=dp) function pmc_scenario::scenario_loss_rate_drydep | ( | real(kind=dp), intent(in) | vol, |
| real(kind=dp), intent(in) | density, | ||
| type(aero_data_t), intent(in) | aero_data, | ||
| type(env_state_t), intent(in) | env_state, | ||
| type(scenario_t), intent(in) | scenario | ||
| ) |
Compute and return the dry deposition rate for a given particle. All equations used here are written in detail in the file doc/deposition/deposition.tex.
- Parameters
-
[in] vol Particle volume (m^3). [in] density Particle density (kg m^-3). [in] aero_data Aerosol data. [in] env_state Environment state. [in] scenario Scenario data.
Definition at line 552 of file scenario.F90.
◆ scenario_loss_rate_max()
| real(kind=dp) function pmc_scenario::scenario_loss_rate_max | ( | type(scenario_t), intent(in) | scenario, |
| real(kind=dp), intent(in) | vol, | ||
| type(aero_data_t), intent(in) | aero_data, | ||
| type(env_state_t), intent(in) | env_state | ||
| ) |
Compute and return the max loss rate function for a given volume.
- Parameters
-
[in] scenario Scenario data. [in] vol Particle volume (m^3). [in] aero_data Aerosol data. [in] env_state Environment state.
Number of density sample points.
Definition at line 928 of file scenario.F90.
◆ scenario_modal_drydep_velocities()
| subroutine pmc_scenario::scenario_modal_drydep_velocities | ( | type(scenario_t), intent(in) | scenario, |
| type(aero_dist_t), intent(in) | aero_dist, | ||
| real(kind=dp), intent(in) | moment, | ||
| real(kind=dp), intent(in) | density, | ||
| type(env_state_t), intent(in) | env_state, | ||
| real(kind=dp), dimension(:), intent(inout) | velocities | ||
| ) |
Updates an array to contain the integrated deposition velocities for the given moment of each aerosol mode in the distribution.
- Parameters
-
[in] scenario Scenario data. [in] aero_dist Aerosol distribution. [in] moment Moment to compute deposition velocities for. [in] density Density for the mode. [in] env_state Environment state. [in,out] velocities Modal dry deposition velocities.
Definition at line 899 of file scenario.F90.
◆ scenario_particle_loss()
| subroutine pmc_scenario::scenario_particle_loss | ( | type(scenario_t), intent(in) | scenario, |
| real(kind=dp), intent(in) | delta_t, | ||
| type(aero_data_t), intent(in) | aero_data, | ||
| type(aero_state_t), intent(inout) | aero_state, | ||
| type(env_state_t), intent(in) | env_state | ||
| ) |
Performs stochastic particle loss for one time-step. If a particle i_part has a scenario_loss_rate() value of rate, then the probability p will be removed by this function is 1 - exp(-delta_t*rate). Uses an accept-reject algorithm for efficiency, in which a particle is first sampled with rate 1 - exp(-delta_t*over_rate) and then accepted with rate (1 - exp(-delta_t*rate))/(1 - exp(-delta_t*over_rate)).
- Parameters
-
[in] scenario Scenario data. [in] delta_t Time increment to update over. [in] aero_data Aerosol data. [in,out] aero_state Aerosol state. [in] env_state Environment state.
Definition at line 1011 of file scenario.F90.
◆ scenario_try_single_particle_loss()
| subroutine pmc_scenario::scenario_try_single_particle_loss | ( | type(scenario_t), intent(in) | scenario, |
| real(kind=dp), intent(in) | delta_t, | ||
| type(aero_data_t), intent(in) | aero_data, | ||
| type(aero_state_t), intent(inout) | aero_state, | ||
| type(env_state_t), intent(in) | env_state, | ||
| integer, intent(in) | i_part, | ||
| real(kind=dp), intent(in) | over_prob | ||
| ) |
Test a candidate particle to see if it should be removed, and remove if necessary. Particle is removed with probability (1d0 - exp(-delta_t*rate))/over_prob, where rate is the loss function evaluated for the given particle.
- Parameters
-
[in] scenario Scenario data. [in] delta_t Time increment to update over. [in] aero_data Aerosol data. [in,out] aero_state Aerosol state. [in] env_state Environment state. [in] i_part Index of particle to attempt removal [in] over_prob Overestimated removal probability used previously
Definition at line 1096 of file scenario.F90.
◆ scenario_update_aero_binned()
| subroutine pmc_scenario::scenario_update_aero_binned | ( | type(scenario_t), intent(in) | scenario, |
| real(kind=dp), intent(in) | delta_t, | ||
| type(env_state_t), intent(in) | env_state, | ||
| type(env_state_t), intent(in) | old_env_state, | ||
| type(bin_grid_t), intent(in) | bin_grid, | ||
| type(aero_data_t), intent(in) | aero_data, | ||
| logical, intent(in) | do_aero_dilution, | ||
| type(aero_binned_t), intent(inout) | aero_binned | ||
| ) |
Do emissions and background dilution from the environment for a binned aerosol distribution.
See scenario_update_gas_state() for a description of the model.
- Parameters
-
[in] scenario Scenario data. [in] delta_t Time increment to update over. [in] env_state Current environment. [in] old_env_state Previous environment. [in] bin_grid Bin grid. [in] aero_data Aero data values. [in] do_aero_dilution Whether to do dilution. [in,out] aero_binned Aero binned to update.
Definition at line 384 of file scenario.F90.
◆ scenario_update_aero_modes()
| subroutine pmc_scenario::scenario_update_aero_modes | ( | type(aero_dist_t), intent(inout) | aero_dist, |
| real(kind=dp), intent(in) | del_t, | ||
| type(env_state_t), intent(in) | env_state, | ||
| real(kind=dp), intent(in) | density, | ||
| type(scenario_t), intent(in) | scenario | ||
| ) |
Update the modal aerosol distribution to account for particle loss.
- Parameters
-
[in,out] aero_dist Aerosol distribution. [in] del_t Timestep. [in] env_state Environment state. [in] density Particle density (kg m^-3), assumed uniform across all modes. [in] scenario Scenario data.
Definition at line 441 of file scenario.F90.
◆ scenario_update_aero_state()
| subroutine pmc_scenario::scenario_update_aero_state | ( | type(scenario_t), intent(in) | scenario, |
| real(kind=dp), intent(in) | delta_t, | ||
| type(env_state_t), intent(in) | env_state, | ||
| type(env_state_t), intent(in) | old_env_state, | ||
| type(aero_data_t), intent(in) | aero_data, | ||
| type(aero_state_t), intent(inout) | aero_state, | ||
| integer, intent(out) | n_emit, | ||
| integer, intent(out) | n_dil_in, | ||
| integer, intent(out) | n_dil_out, | ||
| logical, intent(in) | allow_doubling, | ||
| logical, intent(in) | allow_halving | ||
| ) |
Do emissions and background dilution for a particle aerosol distribution.
See scenario_update_gas_state() for a description of the model. We additionally scale the number concentration to account for temperature changes.
- Parameters
-
[in] scenario Scenario data. [in] delta_t Time increment to update over. [in] env_state Current environment. [in] old_env_state Previous environment. [in] aero_data Aero data values. [in,out] aero_state Aero state to update. [out] n_emit Number of emitted particles. [out] n_dil_in Number of diluted-in particles. [out] n_dil_out Number of diluted-out particles. [in] allow_doubling Whether to allow doubling of the population. [in] allow_halving Whether to allow halving of the population.
Definition at line 294 of file scenario.F90.
◆ scenario_update_env_state()
| subroutine pmc_scenario::scenario_update_env_state | ( | type(scenario_t), intent(in) | scenario, |
| type(env_state_t), intent(inout) | env_state, | ||
| real(kind=dp), intent(in) | time | ||
| ) |
Update time-dependent contents of the environment. scenario_init_env_state() should have been called at the start.
- Parameters
-
[in] scenario Scenario data. [in,out] env_state Environment state to update. [in] time Current time (s).
Ambient water vapor pressure (Pa).
Ambient pressure (Pa)
Ambient temperature (K)
Definition at line 168 of file scenario.F90.
◆ scenario_update_gas_state()
| subroutine pmc_scenario::scenario_update_gas_state | ( | type(scenario_t), intent(in) | scenario, |
| real(kind=dp), intent(in) | delta_t, | ||
| type(env_state_t), intent(in) | env_state, | ||
| type(env_state_t), intent(in) | old_env_state, | ||
| type(gas_data_t), intent(in) | gas_data, | ||
| type(gas_state_t), intent(inout) | gas_state | ||
| ) |
Do gas emissions and background dilution.
Emissions are given as an areal rate  , and then divided by the current box height
 to obtain a volume rate. There is also a dimensionless rate scaling
 . All input functions are asusumed constant over the timestep, so the concentration
 change is given by
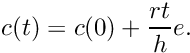
We model dilution by considering a gas concentration in a box of height , subject to first-order dilution with a rate  . Then the effective dilution rate is
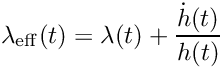
and the evolution of is given by
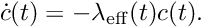
Solving this with separation of variables gives
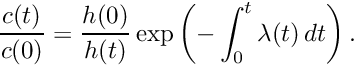
If we define 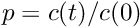 to be the remaining proportion of the initial concentration, and
 to be the constant background concentration, then we have
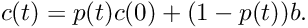
We assume constant  and we only do entrainment with increasing height , so we have
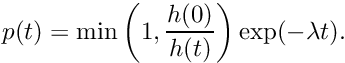
- Parameters
-
[in] scenario Scenario data. [in] delta_t Time increment to update over. [in] env_state Current environment. [in] old_env_state Previous environment. [in] gas_data Gas data values. [in,out] gas_state Gas state to update.
Definition at line 242 of file scenario.F90.
Variable Documentation
◆ scenario_loss_alg_threshold
| real(kind=dp), parameter pmc_scenario::scenario_loss_alg_threshold = 1.0d0 |
Parameter to switch between algorithms for particle loss. A value of 0 will always use the naive algorithm, and a value of 1 will always use the accept-reject algorithm.
Definition at line 45 of file scenario.F90.
◆ scenario_loss_function_chamber
| integer, parameter pmc_scenario::scenario_loss_function_chamber = 5 |
Type code for a loss rate function for chamber experiments.
Definition at line 40 of file scenario.F90.
◆ scenario_loss_function_constant
| integer, parameter pmc_scenario::scenario_loss_function_constant = 2 |
Type code for a constant loss function.
Definition at line 34 of file scenario.F90.
◆ scenario_loss_function_drydep
| integer, parameter pmc_scenario::scenario_loss_function_drydep = 4 |
Type code for a loss rate function based on dry deposition.
Definition at line 38 of file scenario.F90.
◆ scenario_loss_function_invalid
| integer, parameter pmc_scenario::scenario_loss_function_invalid = 0 |
Type code for an undefined or invalid loss function.
Definition at line 30 of file scenario.F90.
◆ scenario_loss_function_none
| integer, parameter pmc_scenario::scenario_loss_function_none = 1 |
Type code for a zero loss function.
Definition at line 32 of file scenario.F90.
◆ scenario_loss_function_volume
| integer, parameter pmc_scenario::scenario_loss_function_volume = 3 |
Type code for a loss rate function proportional to particle volume.
Definition at line 36 of file scenario.F90.